FORCETALLY
Loading the evidence…
Preparing your view.
Preparing your view.
Measured figures
Double Eagle Mark II · Length
Single sourceDouble Eagle original · Length
Single sourceConfiguration
| Specification | 8A4-class ROUV | Double Eagle (mine disposal vehicle) |
|---|---|---|
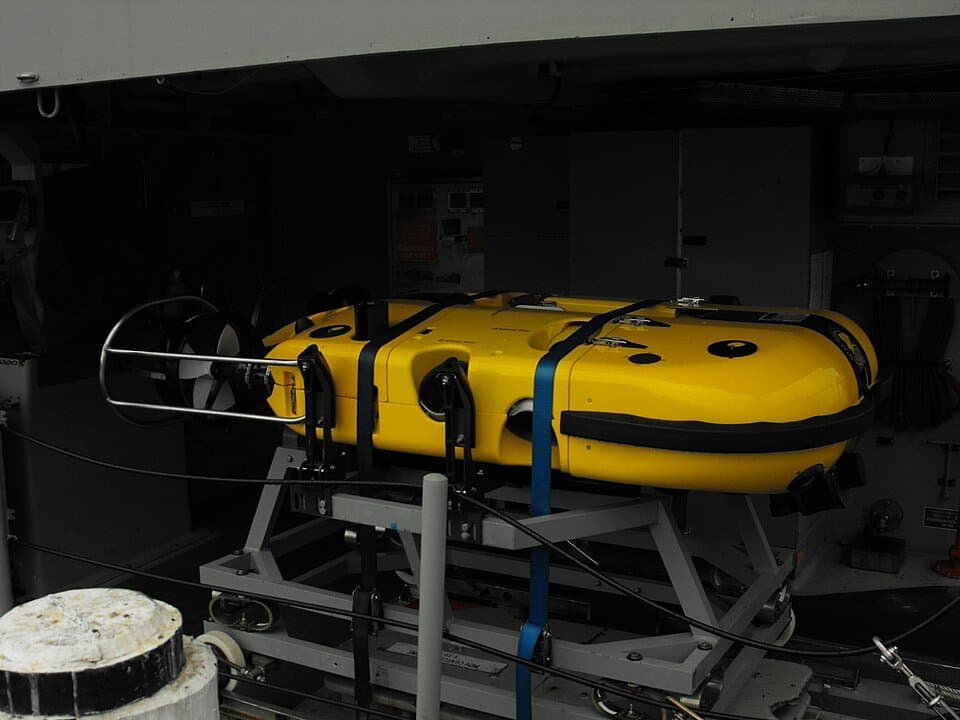
| Type | remotely operated underwater vehicle (ROUV)[source] | remotely operated vehicle (ROV)[source] |
| Role | oil platform service to salvage and rescue missions[source] | disposal of naval mines[source] |
| Designer | the 702nd Research Institute of the China Shipbuilding Industry Corporation (CSIC), the Shipbuilding Engineering Institute of Harbin Engineering University (HEU), and the Institute of Underwater Engineering of Shanghai Jiao Tong University (SHJTU)[source] | — |
| General designer | Xu Huangnan (徐芑南)[source] | — |
First 8A4 unit sea-trial cruising radius 1993, not other ROUVs · up to
Single sourceup to 150 meters[source]First 8A4 unit sea-trial cruising radius 1993, not other ROUVs
Double Eagle Mark II · brushless electric motors for fine manoeuvering
Single sourceDouble Eagle Mark III · four brushless electric motors as main thrusters
Single sourceDouble Eagle Mark II · two brushless electric motors for main propulsion, and six
Single sourcetwo 5 kilowatt brushless electric motors for main propulsion, and six 0.4 kilowatt brushless electric motors for fine manoeuvering[source]
four 7 kilowatt brushless electric motors as main thrusters[source]
Bars compare reported quantities only. A larger figure does not make a system better; configurations and test conditions differ.
| Manipulator system | two manipulators that could operate around half a dozen tools[source] | — |
|---|
| Tether management | Tether Management System (TMS)[source]Original full-performance TMS configuration; later units had TMS removed | — |
|---|
| Maximum operating depth | up to 600 meters[source]First 8A4 unit sea trials 1993 with TMS, not later reduced-performance units | — |
|---|
| Configuration limitation | Except for the first unit, all the remaining 8A4 ROUVs have had their TMS removed due to the budget cuts, resulting in a significant reduction in performance, such as reducing the maximum operational depth by more than half[source] | — |
|---|
| Country of origin | China[source] | Sweden[source]Inventory Origin column; table 3, row 44, cell 4; revision 1374738459; retrieved 2026-09-30 |
|---|
| Design basis reported by article | The Chinese 8A4 class ROUV is a remotely operated underwater vehicle (ROUV) used to perform various underwater tasks, ranging from oil platform service to salvage and rescue missions. The 8A4 is a member of a series of related ROUVs developed by the Shenyang Institute of Automation (SIA) in the People's Republic of China (PRC). The predecessor to the 8A4 was the RECON-IV, an improved version of the American RECON-III. The 8A4 itself is an upgraded version of the American AMETEK 2006, and the 7B8 is an improved version of the 8A4.[source] | — |
|---|
| Manufacturer | — | Saab Underwater Systems AB[source] |
|---|
| Depth | — | 500 metres (1,600 ft)[source] 500 metres (1,600 ft)[source] |
|---|
| Sensors | — | scanning sonar, echo locations , doppler logs , or self-navigation systems[source] |
|---|
| Relative dimensions | — | The Mark III is 80 centimetres (31 in) longer and 130 kilograms (290 lb) heavier than its predecessor.[source] |
|---|